



The product's shade and actual color may differ from what is shown in the picture, as the images are for illustrative purposes. The product description is general and may not include all the product's features.
Robot Arm - UNITREE G1 Dex3-1 L+R Without Touch Sensors
5066977 DX31-214N
5905156112056
This product is no longer in stock
All about the product
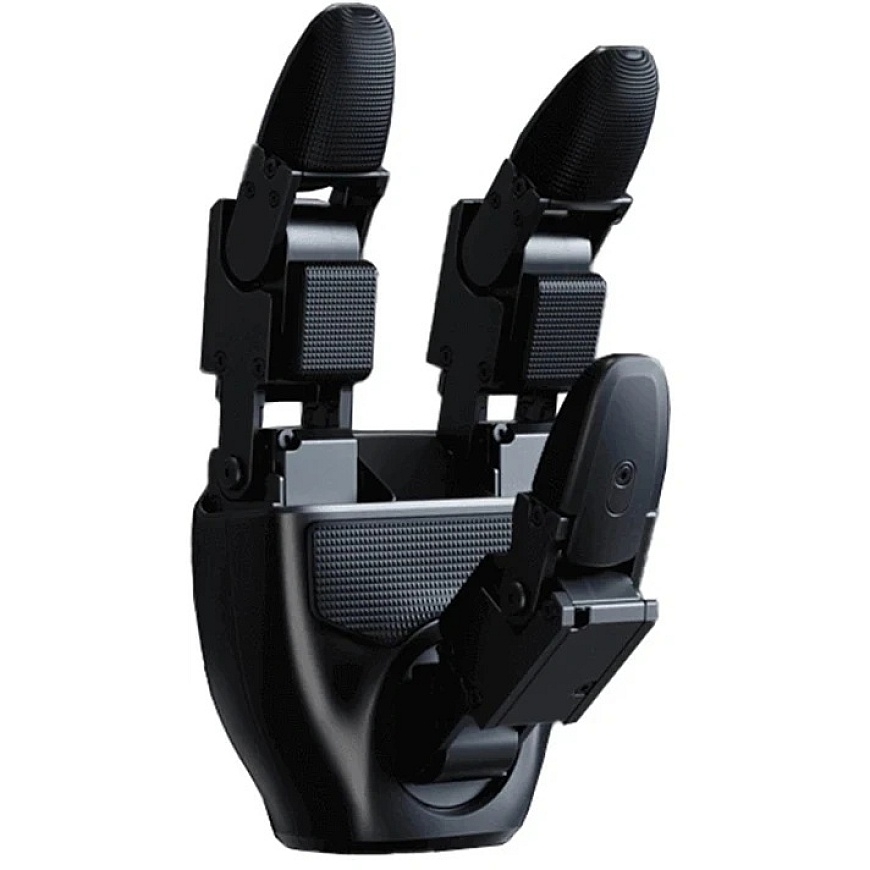
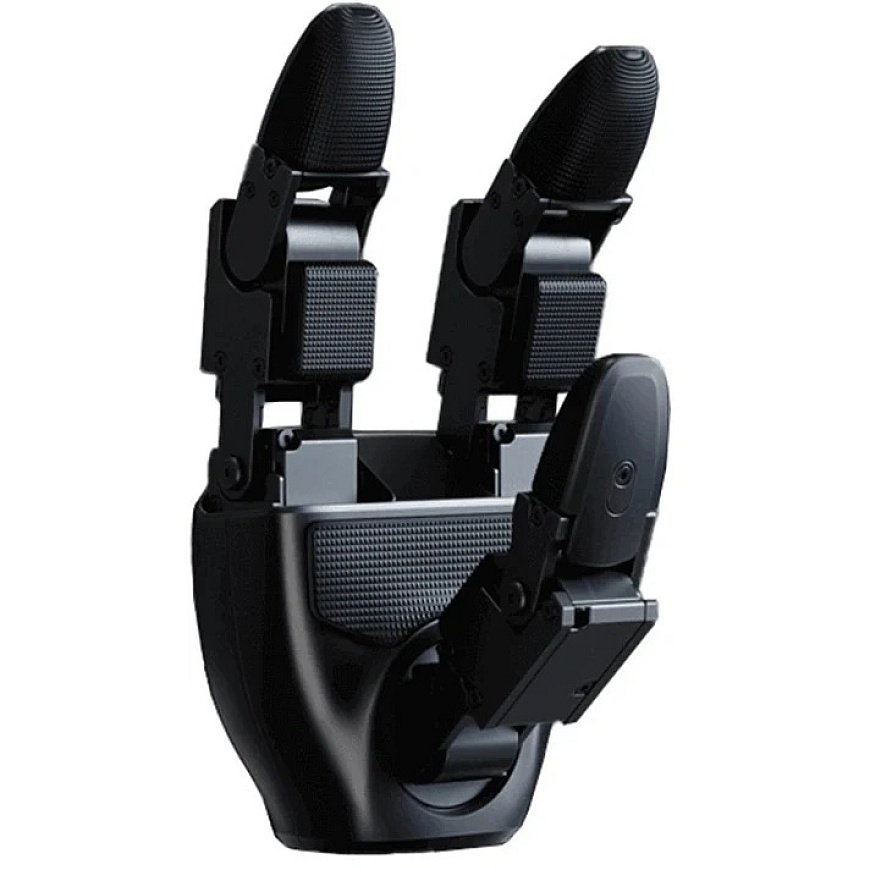
UNITREE G1 Dex3-1 Robotic Arms (Left + Right) Without Touch Sensors
The UNITREE G1 Dex3-1 set includes a left and right three-finger robotic arm designed to work with the UNITREE G1 humanoid robot. Each arm has 7 degrees of freedom and utilizes 7 miniature brushless motors with force control. The hybrid force and position control allows for precise movement control, with a finger tip positioning repeatability of ±2 mm. A connection frequency of 1,000 Hz, USB 2.0 interface, and a wide feedback spectrum enable complex manipulations and precise operation of the mechanism.
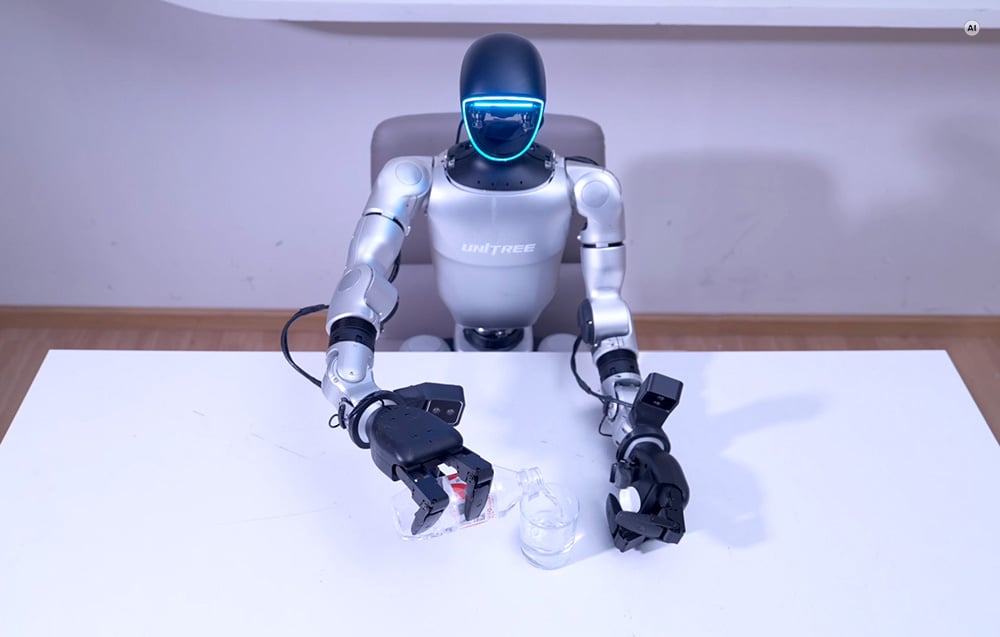
7 Degrees of Freedom for Precise Movement
Each Dex3-1 arm has three moving fingers – the thumb has 3 degrees of freedom, the index finger – 2, and the middle finger – another 2. Each joint’s range of motion allows for complex gripping configurations – the thumb ranges from -60° to 60°, the index finger from -35° to 60°, and the middle finger from 0° to 100°, while the index and middle finger joints operate in ranges of 0° to 90° and 0° to 100° respectively. This design allows the fingers to be repositioned in multiple planes and adapt their configuration to specific tasks. The finger tip positioning repeatability of ±2 mm further assists in executing tasks that require consistent motion reproduction.
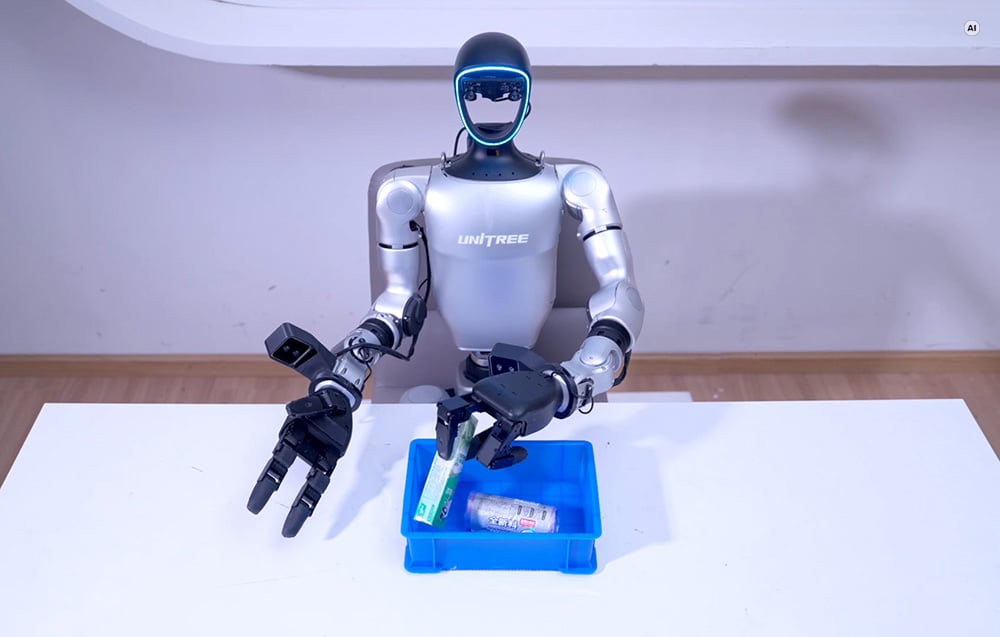
Hybrid Force Control and Advanced Joints
The UNITREE Dex3-1 uses hybrid force and position control, meaning the control is not limited to a specific finger position. Each arm’s construction includes 6 miniature direct drive brushless force control motors and 1 gear motor. F-1515-108 and F-1515-214 models are used, and the system allows control over parameters such as torque, angle, angular velocity, stiffness, and damping. The ideal maximum torque of F-1515-108 is 0.76 Nm, and the rated torque reaches 0.49 Nm in one direction and 1.37 Nm in the opposite direction. For F-1515-214, these values are 1.498 Nm for the ideal torque, and 0.86 Nm and 3.1 Nm for the rated torque respectively.
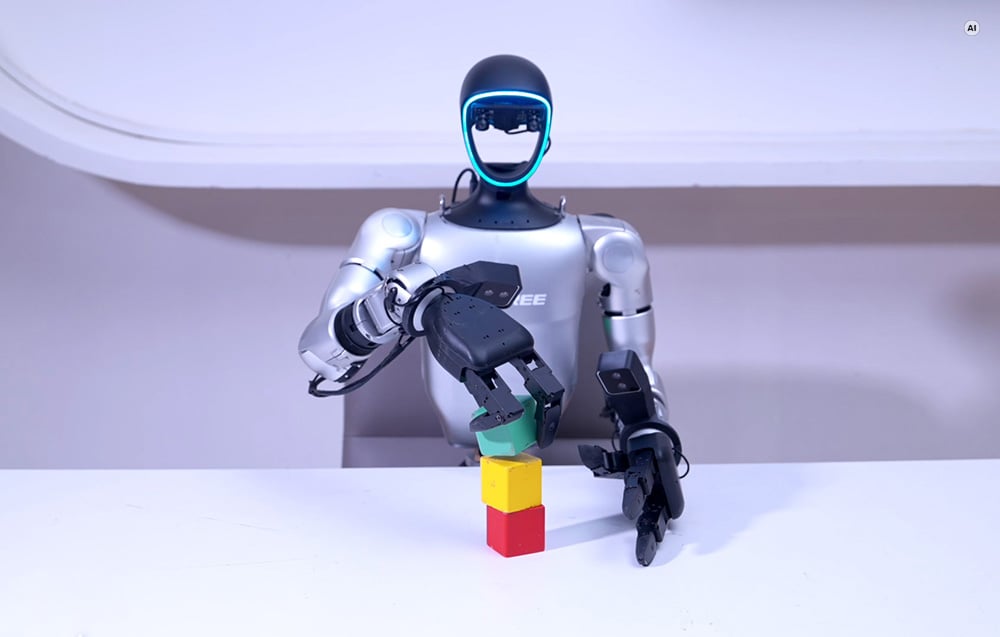
Comprehensive Operating Feedback
The system provides a wide range of information about the current state of the mechanism. Sensor data includes joint mode, position, speed, torque and temperature, as well as voltage, current, and IMU data. Control feedback also includes joint stiffness and damping coefficients. This allows for precise monitoring of the arm's behavior during tasks and the simultaneous use of multiple parameters during motion planning and control.
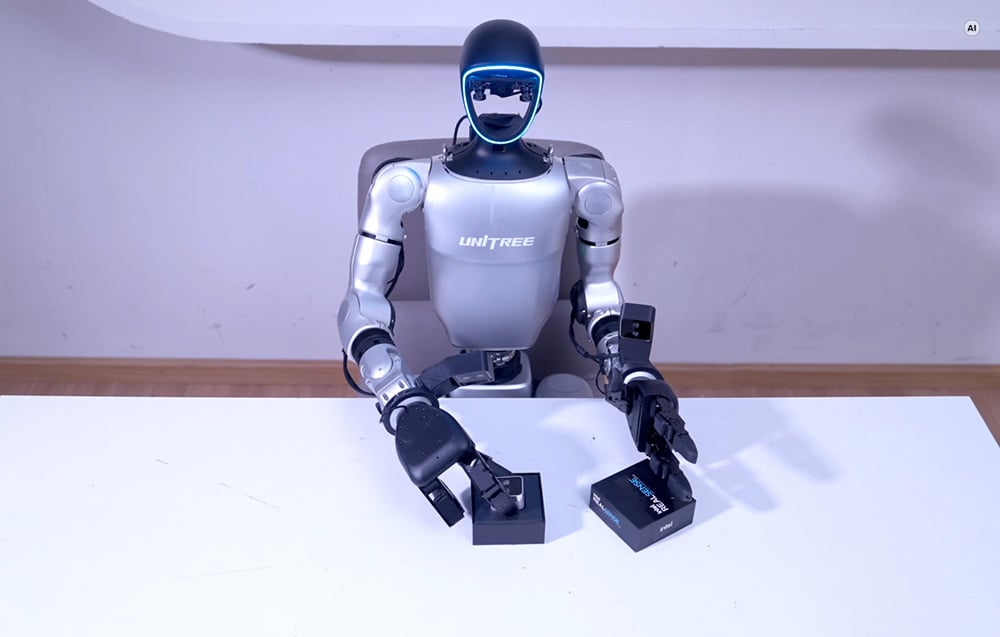
1000 Hz Connection and USB 2.0
The arm's connection interface uses USB 2.0, with a connection frequency of 1000 Hz. The total data packet size for sending is 1,234 bytes, and for receiving is 1,270 bytes. The joint control frequency is also 1,000 Hz, and high-speed unibus is used for joint communication. These parameters provide access to a large amount of information about the arm's status and allow frequent updates of control parameters while executing complex motion sequences.
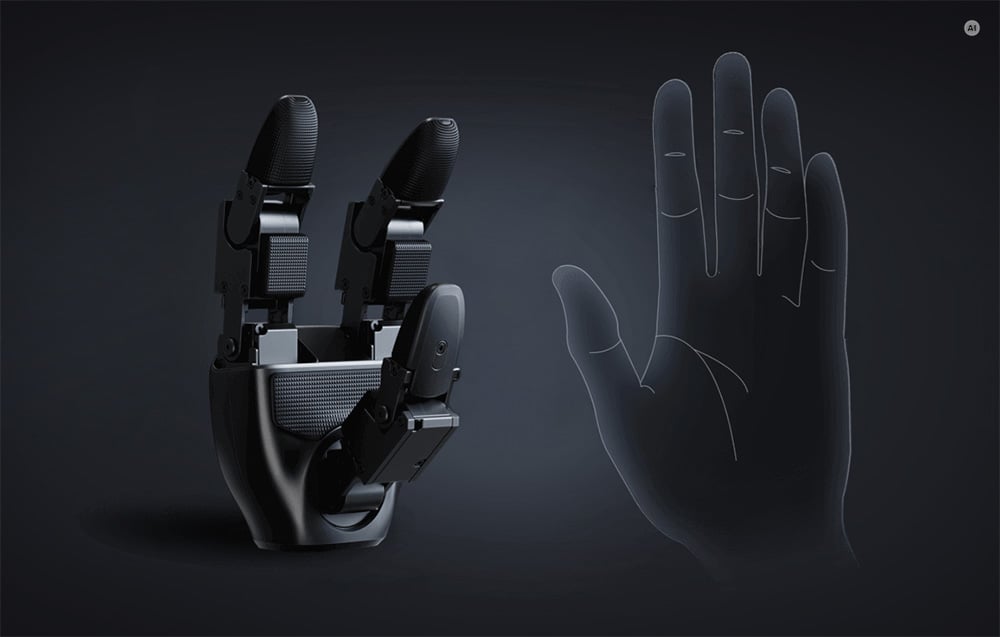
Design Adapted for UNITREE G1 Robot
One arm weighs 710 g, and its dimensions in the extended position are 175 × 88 × 77 mm. The Dex3-1 can work alongside the UNITREE G1 humanoid robot and allows for various complex manipulation tasks. The compact dimensions of the mechanism are combined with an advanced motion control system and feedback system, providing access to a wide spectrum of data about the arm's operation.
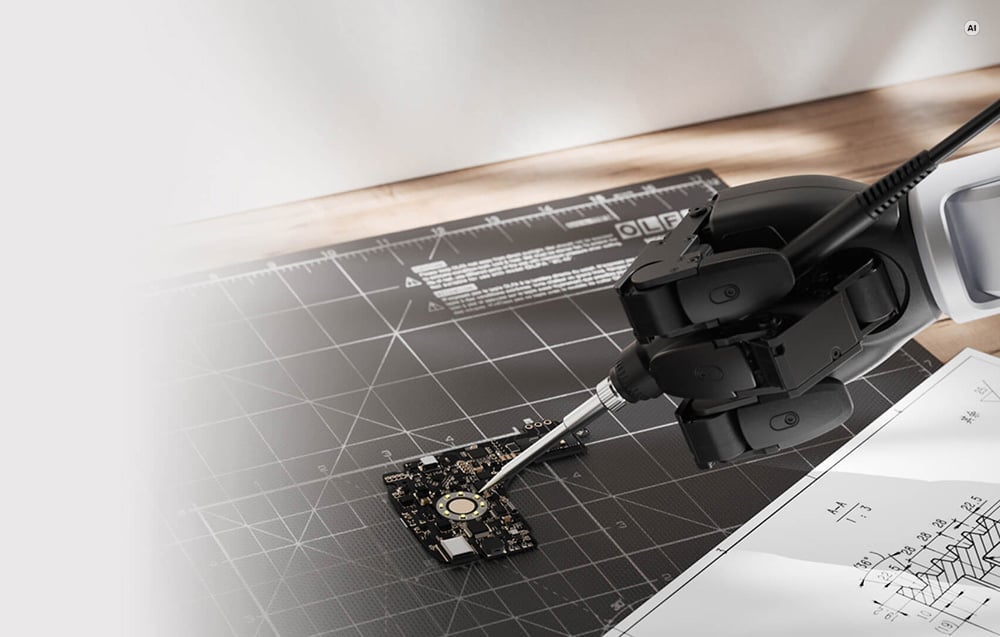
General Information
| Manufacturer | UNITREE |
|---|---|
| Model | DX31-214N |
| Compatibility | UNITREE G1 |
Arm Specifications
| Weight | 710 g |
|---|---|
| Dimensions | 175 × 88 × 77 mm (extended) |
| Degrees of Freedom | Thumb ×3 Index Finger ×2 Middle Finger ×2 |
| Drive Mechanism | 6 direct drive motors 1 geared motor |
| Joint Movement Range | Thumb Joint 0: from -60° to 60° Thumb Joint 1: from -35° to 60° Thumb Joint 2: from 0° to 100° Index Joint 0: from 0° to 90° Index Joint 1: from 0° to 100° Middle Joint 0: from 0° to 90° Middle Joint 1: from 0° to 100° |
| Finger Tip Positioning Repeatability | ±2 mm |
| Operating Voltage | 12–58 V |
| Idle Current | 0.2 A at 58 V |
| Maximum Current | 10 A |
| Communication Interface | USB 2.0 |
| Operating Temperature Range | From -20 °C to 60 °C |
| Load Conditions (palm facing down, room temperature, gripping a solid round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W 3 s |
| Load Conditions (palm facing left, room temperature, gripping a solid round object with a diameter of 5 cm) | Maximum weight: 500 g Maximum power: 400 W 3 s |
Software Features
| Communication Frequency | 1000 Hz |
|---|---|
| Number of Bytes in the Data Packet | Transmitter: 1234 bytes Receiver: 1270 bytes |
| Measurement Feedback Data | Joint Mode Joint Position Joint Speed Joint Torque Joint Temperature Voltage and Current IMU Data |
| Control Feedback Data | Joint Mode Joint Position Joint Speed Joint Torque Joint Stiffness Coefficient Joint Damping Coefficient |
Miniature Brushless Force Control Motor Parameters
| Model | F-1515-108 miniature brushless force control motor F-1515-214 miniature brushless force control motor |
|---|---|
| Weight | 45 g |
| Dimensions | 34.8 × 23.1 × 23.3 mm |
| Gear Ratio | F-1515-108: 1:108 F-1515-214: 1:214 |
| Maximum Torque (Theoretical Value) | F-1515-108: 0.76 Nm F-1515-214: 1.498 Nm |
| Maximum Torque (Actual Value, Torque in the Rotational Direction) | F-1515-108: 0.49 Nm F-1515-214: 0.86 Nm |
| Maximum Torque (Actual Value, Torque Opposing the Rotational Direction) | F-1515-108: 1.37 Nm F-1515-214: 3.1 Nm |
| Maximum Rotational Speed | F-1515-108: 23 rad/s F-1515-214: 11 rad/s |
| Maximum Line Current | 4.76 A |
| Control Communication Frequency | 1000 Hz |
| Communication Method | High Speed Unibus |
| Encoder | Absolute Rotational Position Encoder |
| Operating Temperature Range | From -20 °C to 60 °C |
| IP Protection Class | / |
| Operating Voltage | 12–24 V |
| Motor Feedback Data | Torque Angle Angular Velocity Temperature |
| Motor Control Commands | Torque Angle Angular Velocity Stiffness Damping |