
The product's shade and actual color may differ from what is shown in the picture, as the images are for illustrative purposes. The product description is general and may not include all the product's features.
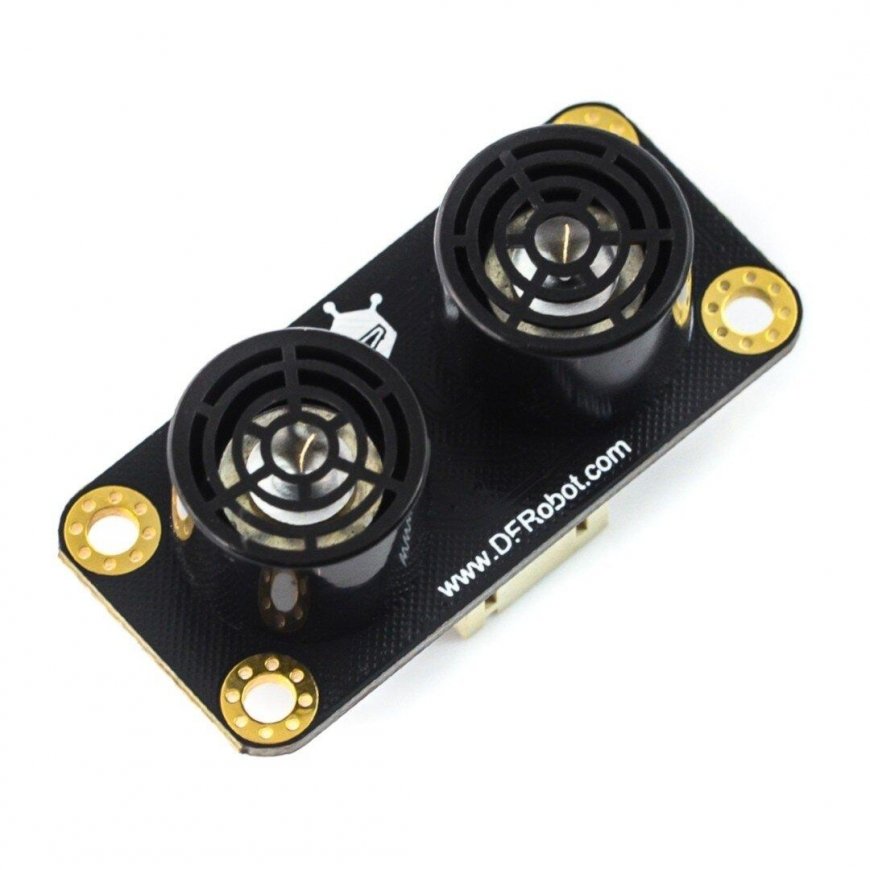
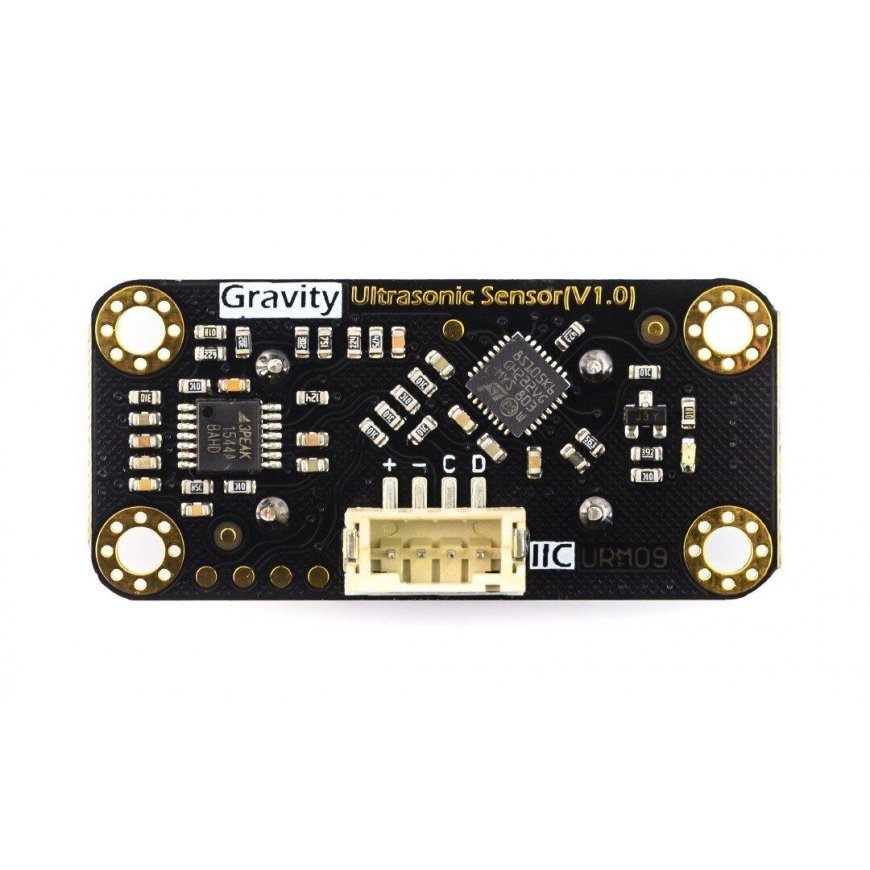
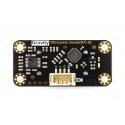
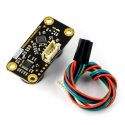
DFRobot Gravity URM09 ultrasonic distance sensor 2-500 cm and temperature sensor I2C
29.00 €
3680086 AN-14048
5904422377441
Shipping 11-18 b.d.
You are interested in this product?
All about the product
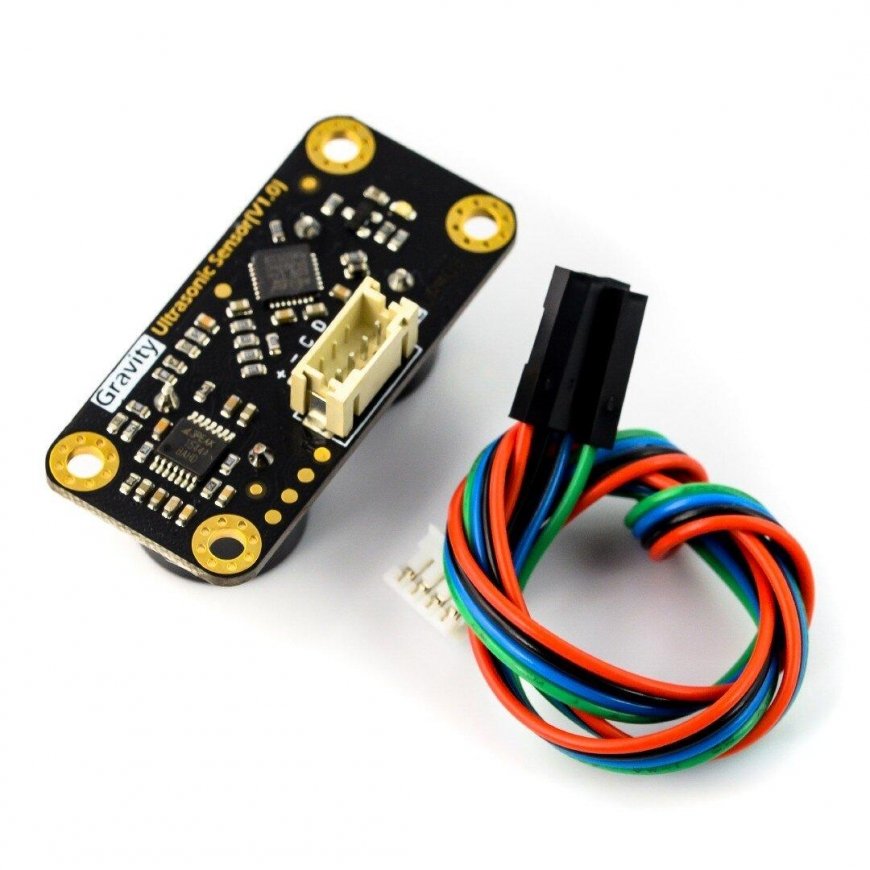
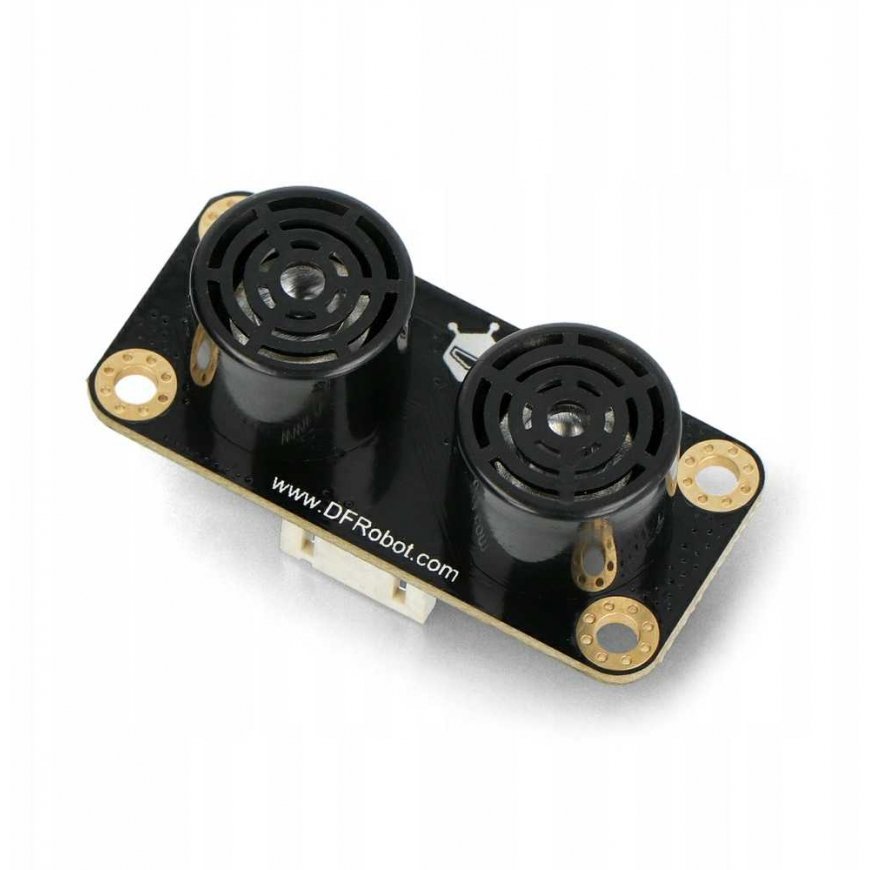
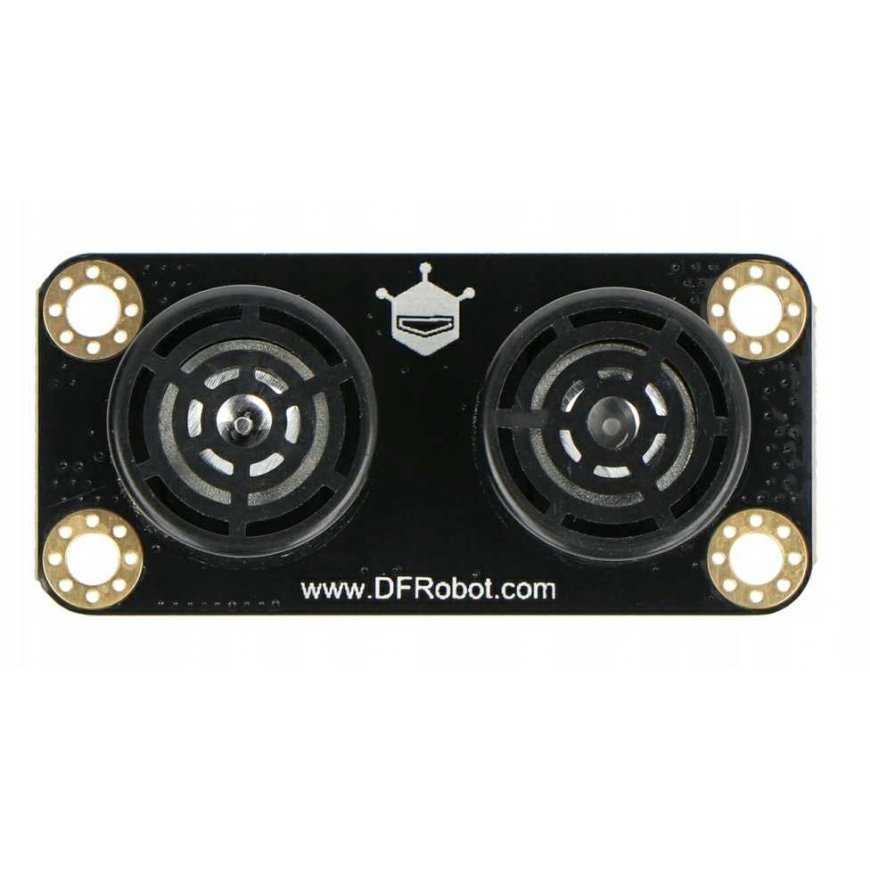
Module with ultrasonic sensor URM09 and three measurement ranges, selectable from 2 to 150 / 300 / 500 cm. This allows you to measure temperature. Supply voltage from 3.3 V to 5.5 V. Works with any controller with an I2C interface, e.g. Arduino, Raspberry Pi. Measurement frequency can reach 50 Hz. Communicates via I2C interface. The kit includes a cable adapted for the DFRobot IO expansion board.
Specifications:
- Supply voltage: 3.3V to 5.5V
- Average current consumption: 20 mA
- Temperature range: -10°C to 70°C
- Distance measurement range: 2 cm to 150 / 300 / 500 cm (adjustable)
- Resolution: 1 cm
- Accuracy: 1%
- Frequency: max. 50 Hz
- Dimensions: 47 x 22 mm
Included:
- Gravity cable x1
Links:
Manufacturer's page
Manual